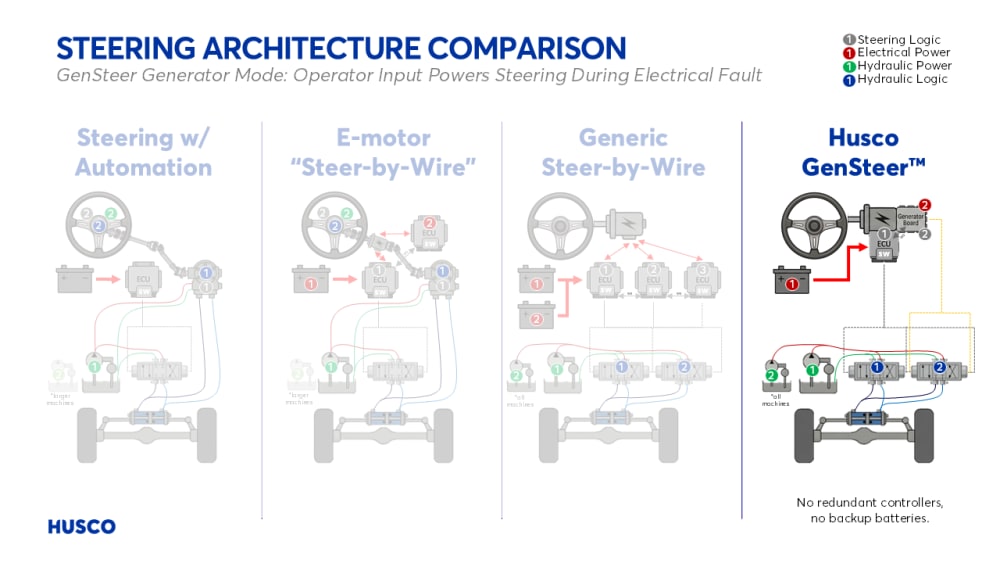


GenSteer is a fail-operational Steer-by-Wire (SbW) system designed to replace conventional orbital and electro-hydraulic steering architectures in Off-Highway vehicles. Traditional systems rely on hydro-mechanical linkages that are robust but limit flexibility, while current Steer-by-Wire implementations require redundant electronic controllers, backup power systems, and complex wiring to achieve fault tolerance. These approaches increase cost, integration complexity, and potential failure points, limiting large-scale adoption.
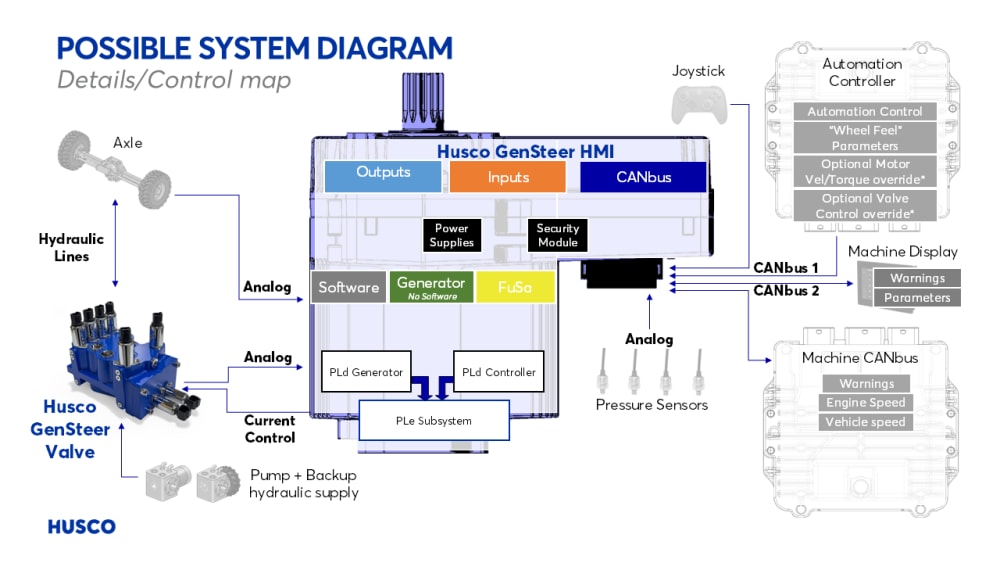
GenSteer introduces a simplified, fail-operational architecture that maintains steering control during electrical faults without redundant electronic subsystems. In normal operation, driver input is captured via steering sensors and processed through an electronic control unit to command electro-hydraulic actuators, while a force-feedback motor provides steering feel. During an electrical fault, the system seamlessly transitions to generator mode, converting the driver’s mechanical input into electrical energy that is immediately used to actuate the hydraulic steering system, maintaining continuous control without external power sources or backup batteries.
Unlike conventional Steer-by-Wire systems that replicate hardware to achieve fault tolerance, GenSteer achieves fail-operational performance through a mechanically driven energy-recovery approach, eliminating the need for duplicate controllers, backup power systems, and complex harnessing. The key innovation lies in replacing redundant electronic architectures with this integrated mechanism, reducing component count, wiring complexity, and overall system cost, and enabling Steer-by-Wire architectures to achieve cost parity with conventional orbital steering systems. By achieving this cost parity, GenSteer removes a primary barrier to Steer-by-Wire adoption.
GenSteer is designed for manufacturability using established technologies, including electric motors, control units, sensors, and hydraulic components, and requires no new manufacturing infrastructure. The system has been demonstrated in prototype applications, validating its functional concept. Leveraging Husco’s 80 years of experience in motion control, GenSteer can be produced at scale using existing supply chains and manufacturing processes while fitting within standard equipment packaging envelopes. The system can be integrated into existing platforms with minimal redesign, enabling rapid deployment across machine fleets.
The system is applicable across agricultural machinery, construction equipment, and material handling vehicles. Its software-defined control architecture enables adaptive steering response, force-feedback tuning, return-to-center, and integration with driver-assist and autonomous systems. This architecture allows OEMs to differentiate machine performance through application-specific steering tuning, creating distinct operator experiences without additional hardware cost. By combining customization with cost parity, GenSteer enables rapid, widespread adoption across the Off-Highway industry.
GenSteer delivers redundancy without replication - enabling fail-operational safety, system simplicity, and cost parity in a single architecture.
Video
Like this entry?
-
About the Entrant
- Name:Allison Salkeld
- Type of entry:teamTeam members:
- Ben Holter
- Dave Joyce
- Tim Opperwall
- Theo Kachelski
- Austin Sowinski
- Nathan Ostrye
- Amber Adams
- Sarah Iselin
- Mike Fossell
- Federico Zappaterra
- Software used for this entry:Matlab/Simulink; Creo
- Patent status:pending