There are 2.7 million miles of pipeline in the United States alone. They carry oil, natural gas, water, and chemical products that power every home, factory, and vehicle in the country. Corrosion and material failure have been responsible for more than 25% of all significant pipeline incidents between 2010 and 2023. In that same period, pipeline failures caused thousands of injuries, dozens of deaths, and billions of dollars in environmental remediation costs.
The inspection technology that catches these defects called an ILI tool or "pig", is a passive device pushed through the pipeline by flow pressure. It records data. It then has to be retrieved, and its data manually downloaded, physically transported, and interpreted by specialists over days to weeks. By the time a defect is classified and a maintenance crew is dispatched, conditions have changed, the defect has grown, and the exact location must be re-surveyed on the ground before repair can begin.
PipeHound replaces this passive inspection paradigm with an active, autonomous one.
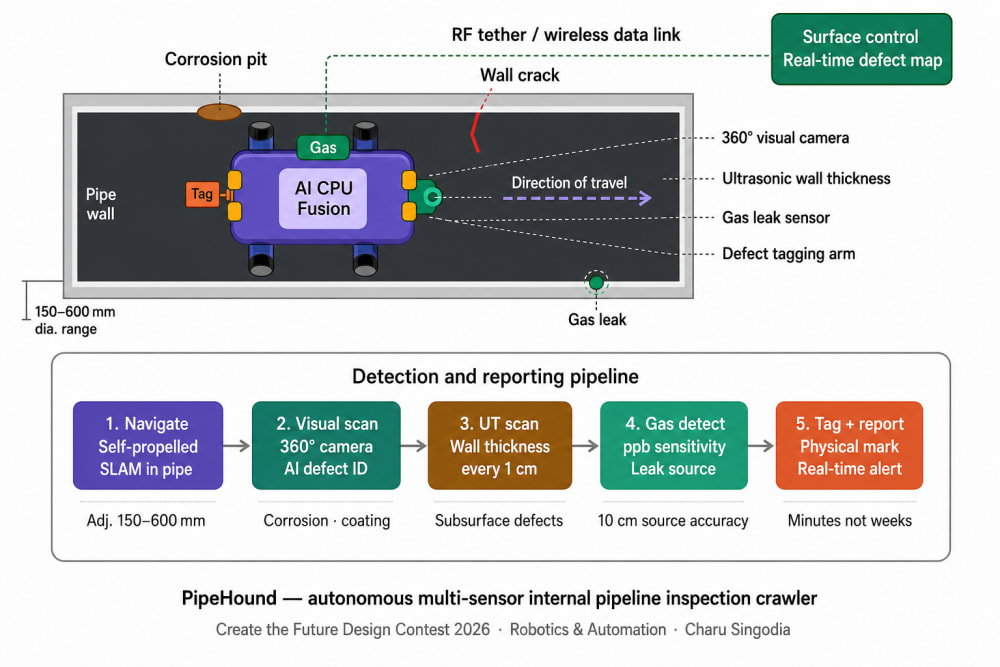
It is a modular self-propelled crawler robot designed to operate inside pipelines from 150mm to 600mm in diameter . Four independently driven polyurethane wheels provide traction against the pipe wall in any orientation: horizontal, vertical, or upside-down. The chassis diameter is adjustable via a pneumatic expansion mechanism, allowing a single unit to inspect multiple pipe sizes on a single deployment.
The sensor payload is the core innovation. PipeHound integrates three real-time inspection modalities that currently exist in isolation but have never been combined in an autonomous crawling platform:
First: a high-resolution 360-degree visual camera system with structured LED illumination maps the internal pipe surface in photographic detail, with an AI vision model running onboard to classify surface defects like corrosion pitting, coating failure, weld anomalies.
Second: a phased-array ultrasonic transducer array, in continuous contact with the pipe wall via spring-loaded coupling pads, measures wall thickness at every point along the crawl path. Thickness below the minimum safe threshold triggers an immediate defect flag regardless of what the camera sees and catches subsurface corrosion invisible to visual inspection.
Third: an electrochemical gas sensor detects trace hydrocarbon concentrations inside the pipe at parts-per-billion sensitivity. A rising gas concentration gradient, cross-referenced with the crawler's position, pinpoints the leak source within 10 centimetres.
All three sensor streams are fused onboard into a unified defect map in real time. When PipeHound identifies a defect that meets the pre-programmed severity threshold, it does something no passive ILI tool has ever done: it physically marks the defect location. A small retractable arm deploys a fluorescent, pressure-sensitive marking compound onto the pipe wall at the exact defect point, creating a permanent visual tag readable by maintenance crews and future inspection cameras without needing GPS coordinate correlation between inspection and repair teams.
The crawler transmits all data wirelessly via an RF tether to a surface control unit, generating a live defect map that maintenance dispatchers can access within minutes of the inspection run. Crawler is retrieved, recharged, and redeployed. One operator. One deployment. Real-time results.
Like this entry?
-
About the Entrant
- Name:Charu Singodia
- Type of entry:teamTeam members:
- Sahil .
- Profession:
- Patent status:none